Axon responsible to determine direction of vehicles.
The VelocityAxon needs at least three frames to determine whether a car is moving towards or away.
The VelocityAxon will add 'direction in' or 'direction out' to the received message (MSG_IMAGE) containing the recognised licensed plate, when direction is determined. When direction is not determined it will not add a MessageInfo
The name of the MessageInfo it adds is: MI_DIRECTION_OUT or MI_DIRECTION_IN.
Sequential Axons use the added MessageInfo to perform actions. The WebserviceAxon uses the MessageInfo in its POST requests, the DataBaseAxon uploads this information to a database. This functionality is implemented with scripting in the trigger panel of the WebserviceAxon and the DataBaseAxon.
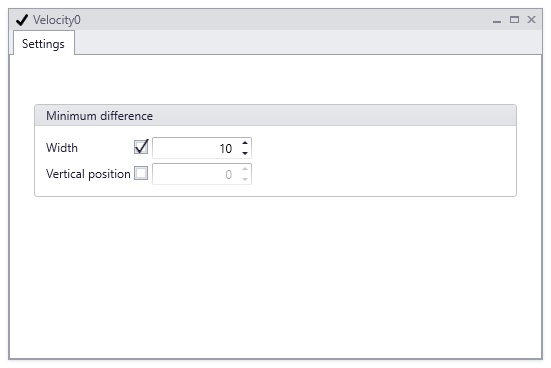
VelocityAxon settings
|
|
|
Direction can be determined in three ways depending on camera projection.
1.Setting width:
Direction is calculated by comparing the width of the first recogned license plate with the sequential recognitions. The value set in this field is the difference required to be able to calculate direction.
When the camera is positioned low, looking straight at a license plate, the width is used to determine direction. In this position the license plate will not move on the image from top to bottom (or from bottom to top).
2.Setting vertical position:
Direction is calculated by comparing the vertical position of the first recognition of a license plate with the sequential recognitions. The value set in this field is the difference required to be able to calculate direction.
When the camera is positioned high, looking from above at a license plate, the vertical position is used to determine direction.
3.Setting both vertical position and width:
Both conditions (values) have to be met before direction can be determined. This setting can be done, but is not recommended. |
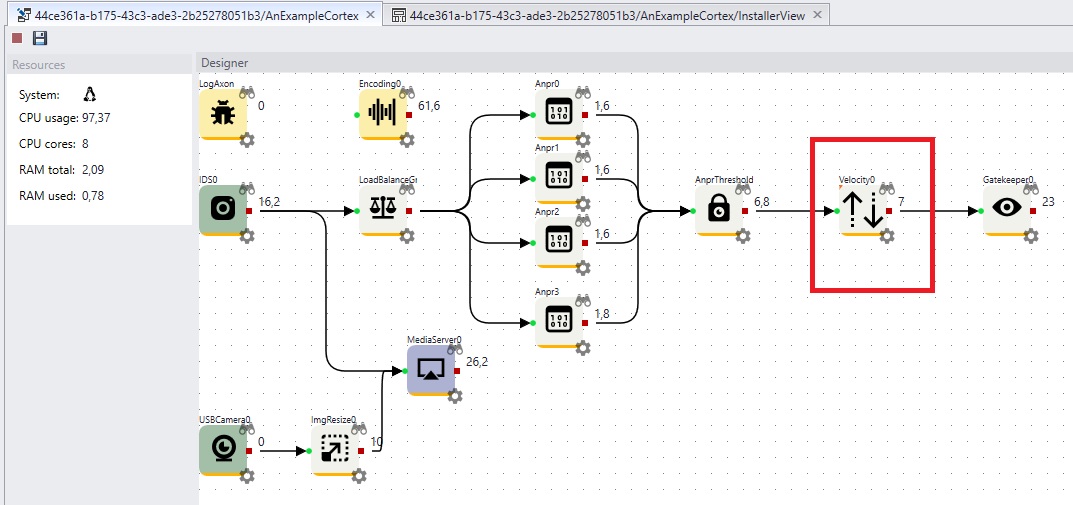
Example of the VelocityAxon in combination with the GatekeeperAxon
|
|
|
The position of the VelocityAxon in the Cortex in this example is after the AnprThresholdAxon and before the GatekeeperAxon.
The functionality required in this sample : GatekeeperAxon will open the gate when the threshold is met AND direction is in.
In order to implement this behavior the following is important.
1.The settings of the ANPRThresholdAxon
The VelocityAxon needs three frames to determine whether a car is moving towards, away or in unknown direction. When direction is determined it will add MI_DIRECTION_OUT or MI_DIRECTION_IN to MSG_IMG.
In this example the threshold for the ANPRThresholdAxon needs to be at least 4. If the threshold is below 4 the license plate will be given a 'threshold passed' before direction can be determined. Threshold passed is given to a license plate only once.
2.The settings of the VelocityAxon
See above paragraph.
Important
When the threshold is set too low the message reaching the GatekeeperAxon will contain only one message:
threshold passed (MI_ANPR_THRESHOLD). The gate will not open.
When the threshold is set above 4 the message reaching the GatekeeperAxon will contain two messages: threshold passed and direction towards or away . The GatekeeperAxon will decide based on the messageinfo to (not) open a gate.
|